SeaPRwire – Physicl said on November 6 that it raised $10 million in seed funding led by Inovia Capital. The company sells simulated 3D rooms that robot developers use to generate training data, and its pitch rests on a claim that is simple to state and hard to audit: that a synthetic kitchen can stand in for a real one closely enough to teach a machine how to move through it.
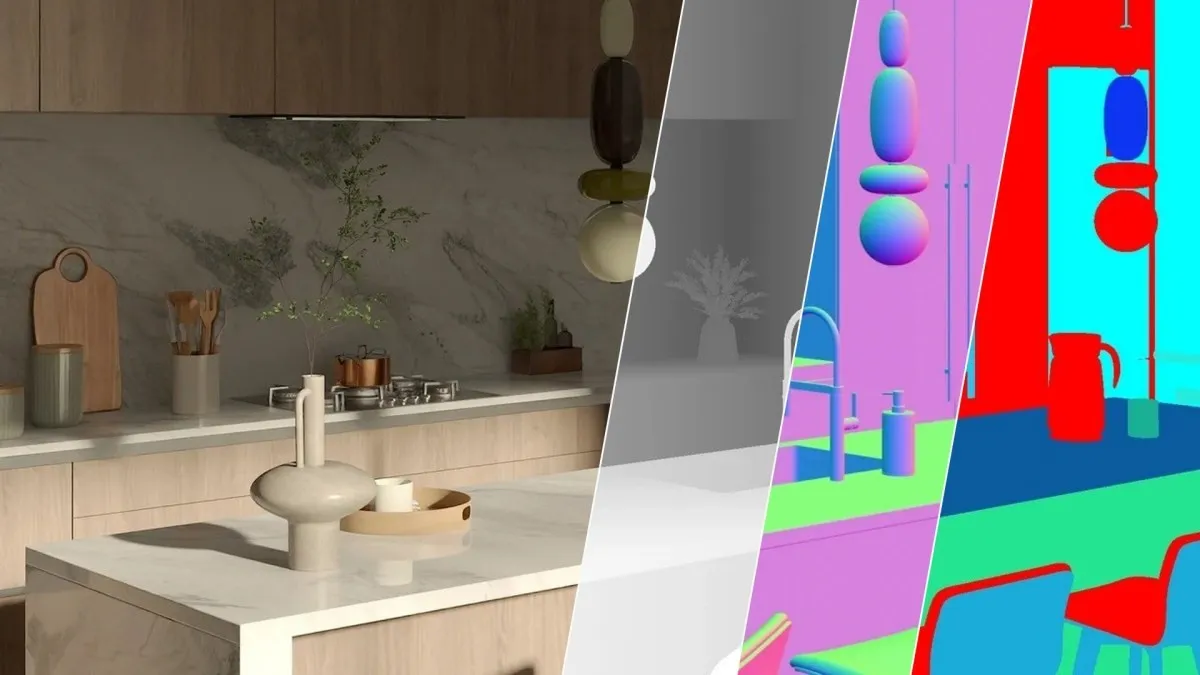
Alex de Vigan, the founder and chief executive, arrived from e-commerce. He spent a decade building nfinite, a company that let brands and retailers produce 3D product renders for online storefronts. Transformer-based image models took over most of that work, and the rendering stack his team had assembled lost the market it was built for.
“What we were super unique about doing in 3D, AI was going to replace, but something was missing in AI: its ability to understand, interact, and manipulate space and objects,” he said.
What went missing was the part of a scene that an image model never has to represent: where surfaces actually are, what they are made of, and how they behave when something pushes against them. A convincing render only has to survive a glance from one fixed camera angle.
Robot developers have two established ways to get training data, and both carry costs that compound. Video is abundant, but its returns have frustrated teams working on manipulation of small, varied objects, because footage shows outcomes without showing the forces behind them. Teleoperation produces accurate demonstrations and consumes human hours in proportion to the data collected.
Simulation sits between the two. It can generate volume and label it precisely, since the engine already knows every object’s position, mass and material. The difficulty is the gap between the simulated world and the physical one, which shows up as a policy that scores well in a virtual kitchen and stalls on a real counter. Physicl’s argument is that the gap narrows when the scene is reconstructed from measurements of real spaces instead of being authored by an artist, and that the reconstruction preserves what a renderer normally throws away. De Vigan describes the pipeline his previous company built as one that can “transform unstructured, incomplete, heterogeneous real-world information into a high-fidelity physical representation… with correct geometry, materials, and physics.”
Studio, the product shipping now, contains 10,000 environments and 100,000 assets. Users assemble scenes and generate synthetic data for a named failure mode: a cup on a cluttered counter-top, or the same cup sitting in shadow. That framing matters. It treats synthetic data as a repair kit for specific weaknesses found during evaluation, not as a substitute for an entire training corpus.
That is a narrow brief. It is also the one a robot team can grade.
Post-training is where Physicl says it wants to work. The company is not trying to supply the bulk pretraining set that teaches a model general physical intuition. It is aiming at the smaller, more tedious stage where a model that mostly works is corrected on the cases it still fails.
SpAItial, which builds world models, used Physicl as an early customer. Its latest product, Echo-3, released last week, generates 3D simulations from 2D imagery. Matthias Niessner, the company’s founder and chief executive and a professor of robotics at the Technical University of Munich, said the fidelity of that output depends on training against high-fidelity synthetic data of the kind Physicl produces.
Niessner’s complaint about the current workflow is about labor, not compute. “The real challenge is, you have to curate the data by hand, and this is a very long cycle,” he said.
He wants the loop closed. In his description, an agent monitors a training run, notices that one class of scenes is under-represented, and generates more of them while the run is still going. He named Claude as the model in that loop. “That, to me, is super exciting, and this is exactly what Physicl is offering,” he said.
De Vigan’s version of the same idea is larger in scale and vaguer in mechanism. He imagines customers feeding in trillions of images or millions of hours of lidar capture, converting them into 3D representations, and then generating billions of permutations from each. “What we created 10 years ago, without knowing it, was basically an agentic workflow to transform unstructured information into high-fidelity 3D,” he said.
The category he is entering has no shortage of entrants. Companies collect robot data in factories, record human demonstrations with instrumented gloves, license synthetic scenes, and sell annotation pipelines. Asked about the competition, de Vigan did not claim a technical lead. “The space is very young and very blurry sometimes,” he said.
Blurry is the right word for the buyer’s problem. A robotics team evaluating a synthetic data vendor has to answer a question that no demo reel settles: does a policy trained on these scenes perform better on hardware, on tasks it has not seen, than a policy trained on cheaper or older data? That comparison requires a fixed evaluation suite, a consistent robot platform, and weeks of runs.
The funding announcement does not include several numbers that would make the claim testable. There is no disclosed pricing, no customer count beyond the single named partner, no statement of how many scenes a typical customer generates, and no measured improvement in real-world task success. Those are the figures that would separate a rendering company with a new market from a data company with a defensible one.
Physicl is also selling tooling rather than a finished dataset, which shifts part of the burden to the customer. A team that buys Studio still has to know which failures to target, build the scenes, run the generations, and retrain. The product reduces the cost of producing a specific kind of example. It does not decide which examples are missing.
None of that makes the bet unreasonable. The rendering pipeline behind nfinite was built to satisfy retail clients who rejected plastic-looking surfaces, and the same obsession with material accuracy is what simulation for manipulation needs. The question is whether that accuracy survives contact with contact physics, where friction, deformation and compliance decide whether a grasp holds.
De Vigan’s own framing suggests he knows where the burden of proof sits. The pitch is not that synthetic worlds replace real ones, but that they cover the cases a real-world collection program would take months to find and label. Whether that holds is a result nobody has published yet, from Physicl or from the customers it says are already using the tooling.